


Manipulation & household tasks
Capture varied human demonstrations and robot interactions across natural environments.
Coverage programs
A coverage program turns a brief into coverage cells and capture configurations. It records failures and recoveries alongside successes, and every delivery ships with a coverage report.
Every coverage program draws its cells from Avala's catalog of 218 workflows.
Choose a capture setup| Setup to discuss | What to check on a representative recording |
|---|---|
| Egocentric capture | Which camera view shows the hands and objects? Check frame timestamps against the task labels. Identify any hand pose estimated from video. Hand-action fields |
| Robot teleoperation | Which channels record commands and measured joint state? Check their time alignment and joint order in the exported trajectory. LeRobot state and action mapping |
| Custom sensor rigs | For an instrumented gripper, which sensor measures contact? Specify axes, units and calibration. Mark inferred contacts separately in the export. Custom MCAP schemas |
| Field operations | For a mobile robot or vehicle, which streams must align? Agree on frames, clock sources and a timing tolerance. Check alignment after a sensor remount. Supported sensor messages |
Use the same task across different spaces to see what changes. Include the objects, camera perspective and conditions you need in the collection brief.
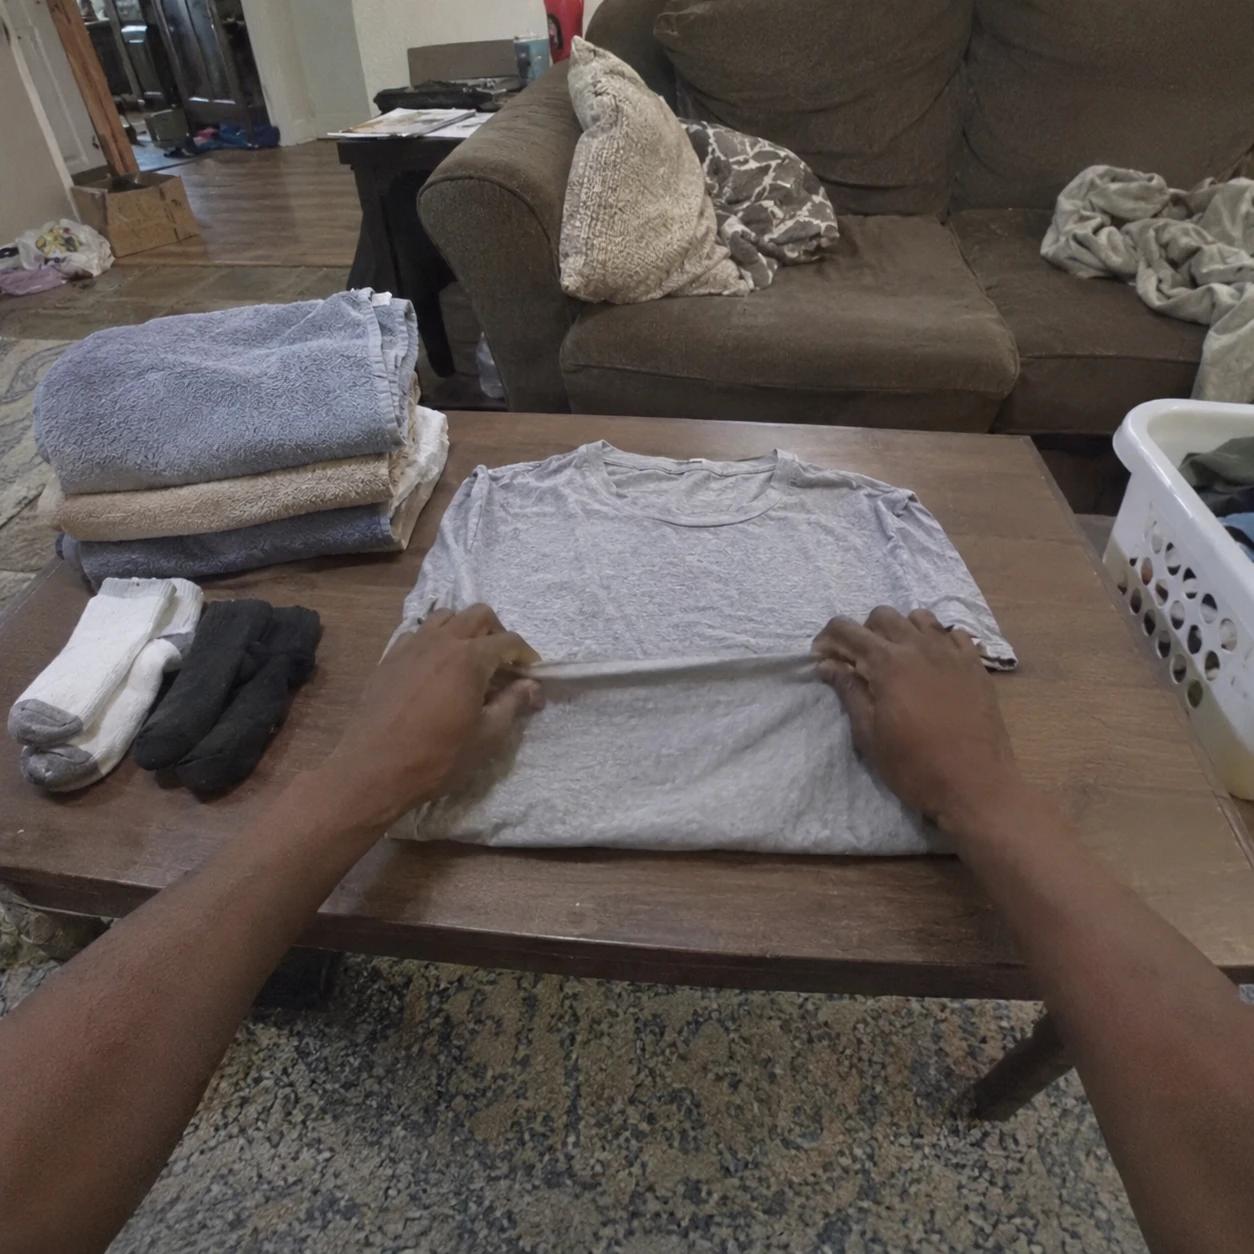
For laundry, vary garment size, fabric and folding surface.
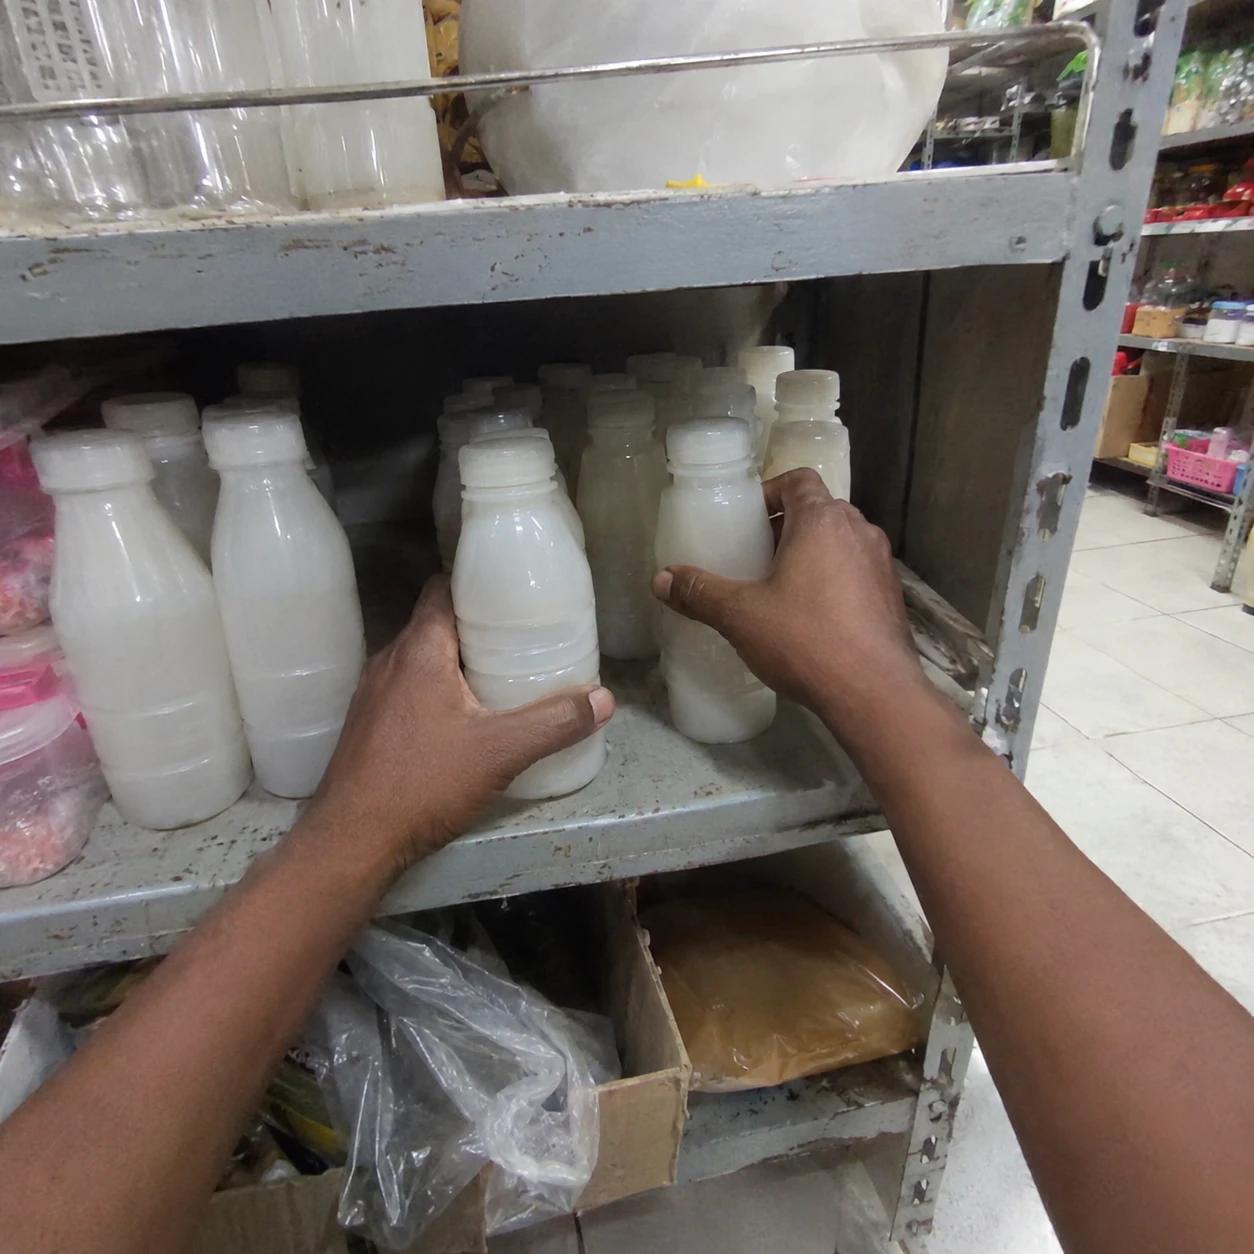
For shelf replenishment, specify the shelf height, item packaging and arrangement.
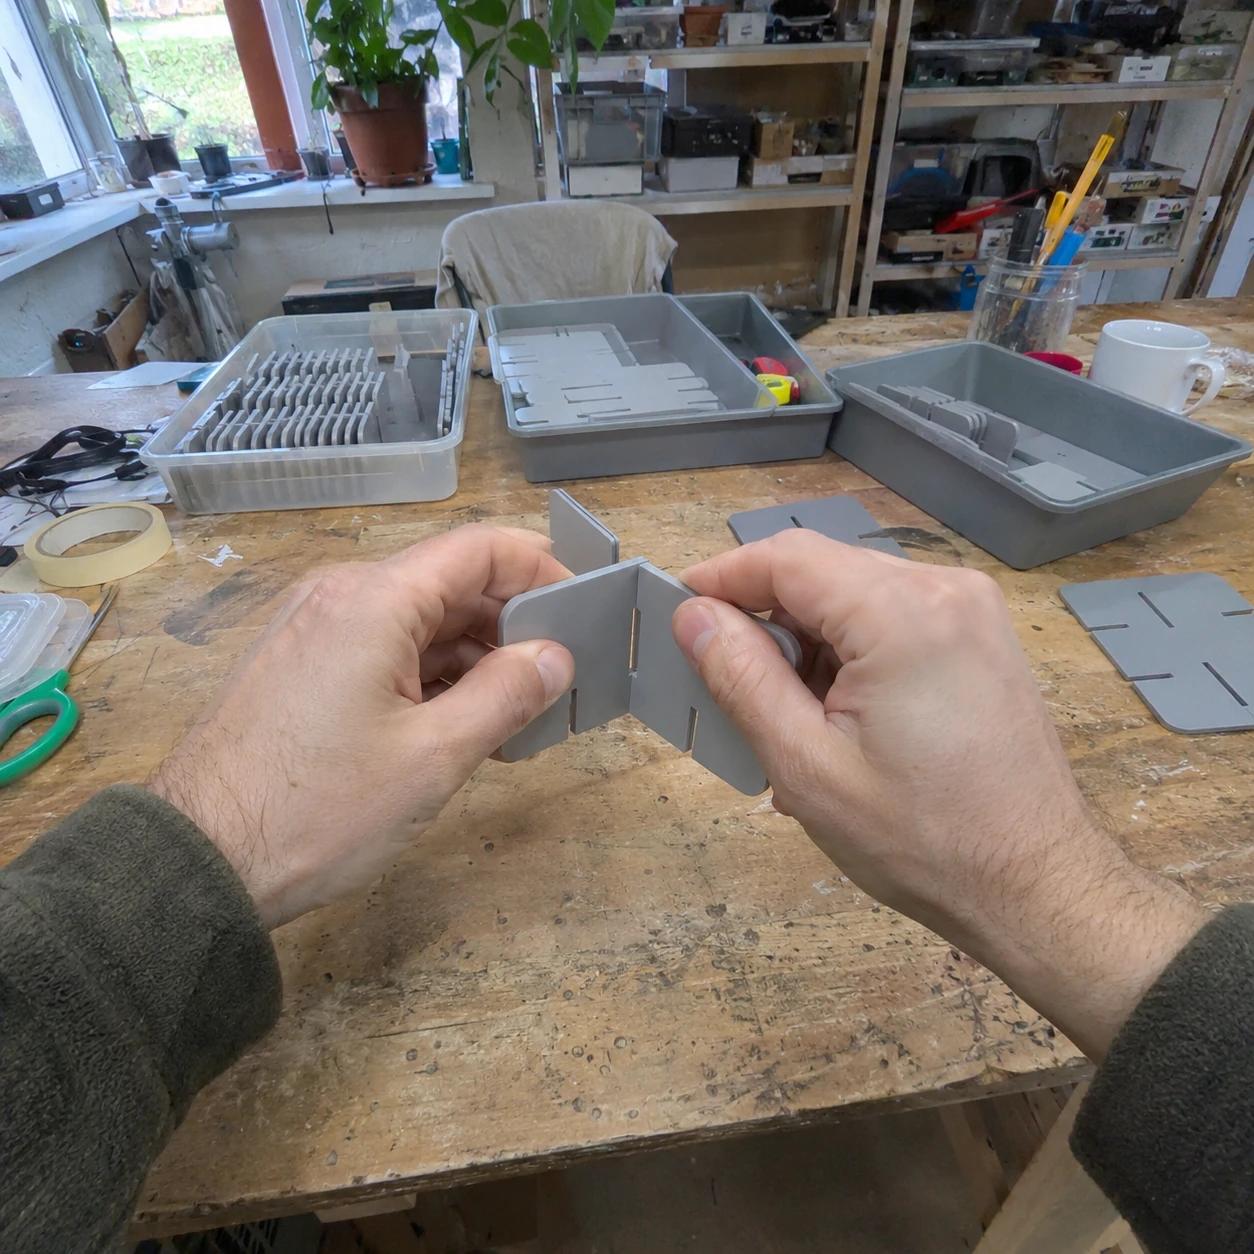
For assembly, define the part orientation, tool and camera view needed to see each step.
How a coverage program runs
Each part is set before capture starts or checked after it ends, so every delivery traces back to the gap it was meant to close.
A collection brief names the gap: tasks, settings, objects, sequence counts and acceptance criteria. Your team approves it before capture starts.
Choose combinations of setting, mechanism, material, action, failure mode and embodiment that matter to the task. Set a coverage target for each combination.
Mistakes, recoveries and interventions are labeled and delivered as their own lane. They show your model how to get back on track.
Each campaign fixes the capture mode, rig, sensors and calibration, and records them on every sequence.
Every delivery ships with a report that compares what was captured with the brief, cell by cell.
Per-delivery coverage report
The coverage report compares each delivery with its brief. It shows which cells are complete, where the data is thin and where it is concentrated.
Programs
Run focused programs across human demonstration, robot interaction, mobile autonomy, and industrial work.
Capture varied human demonstrations and robot interactions across natural environments.
Build coverage for pick-and-place, sorting, palletizing, and inventory workflows.
Collect edge cases across navigation, weather, terrain, and human interaction.
Record tool use, assembly, inspection, and contact-rich tasks with the context training teams need.
Use this checklist to scope a benchmark with Avala or another provider. Agree on evidence and acceptance criteria before work starts. Checking a box records your review in this page only; it does not certify a provider or submit a request.
Blank planning templates in English. Define requirements and record evidence before agreeing on a program. These files contain no results or commercial terms.
Data partners
Robot fleets, teleoperation centers, capture studios and sensor-rig builders are paid per accepted hour, keep their rights on stated terms, and are never pooled with another customer's data.
Start with one gap
Bring your rollouts or your task list. We map them to coverage cells and draft the first brief with you.